
 By Nana
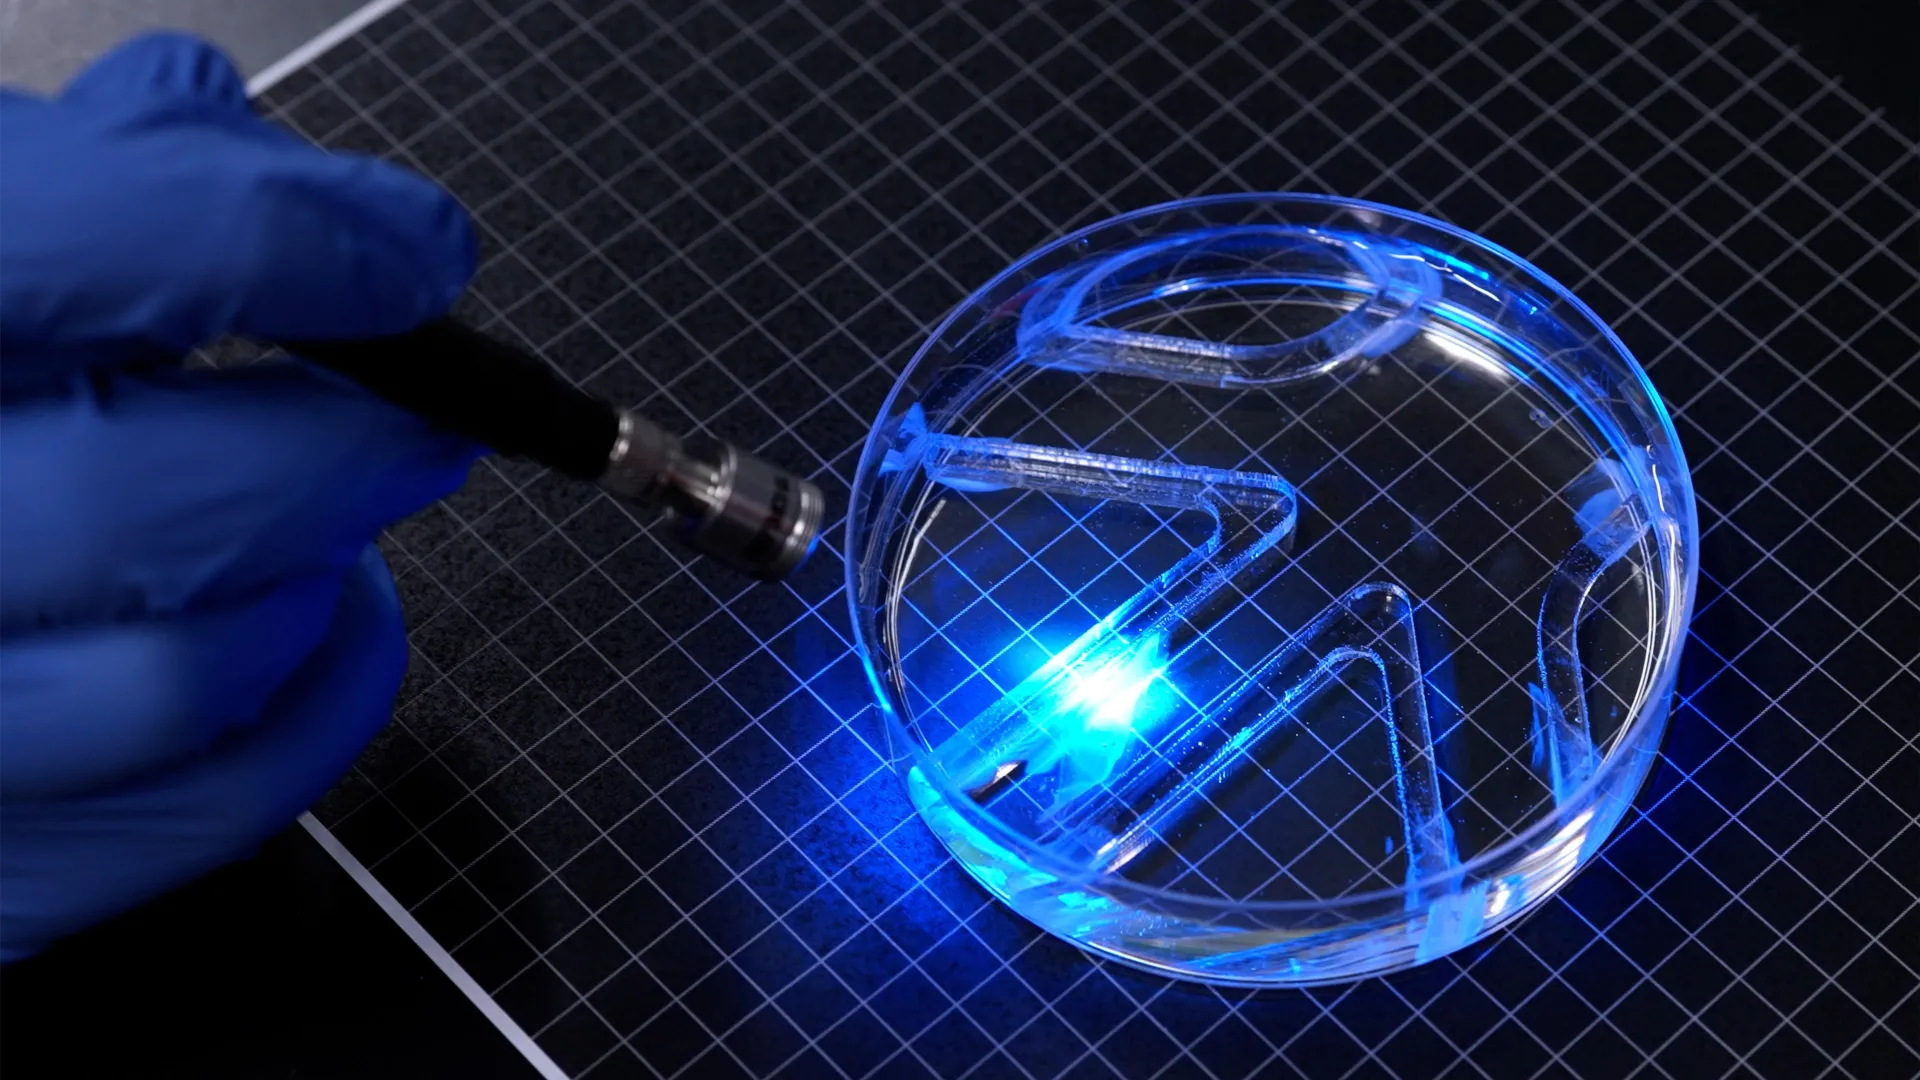
In the quest to create robots that can interact seamlessly with delicate environments, engineers have long looked toward the natural world for inspiration. However, a team of researchers at the Massachusetts Institute of Technology (MIT) has moved past mere biomimicry. They have successfully bridged the gap between synthetic engineering and biological autonomy, demonstrating that a single, meticulously engineered layer of living muscle cells is sufficient to propel a robotic device through water.
This breakthrough, published in the journal Advanced Functional Materials, represents a significant departure from conventional robotics. By eschewing bulky, energy-intensive motors and rigid mechanical actuators in favor of biological tissue, the MIT team has unveiled a two-dimensional, swimming robot that is as soft and responsive as it is technologically profound.
The Anatomy of a Living Machine
The robot itself is deceptively simple in appearance. Roughly the length and width of a standard stick of gum, the device consists of a flexible, lightweight gel framework bifurcated into two distinct fins. The true innovation lies in what coats these fins: a layer of skeletal muscle cells thinner than a single human hair.
These cells are not merely passive attachments; they have been genetically engineered to be optogenetic—meaning they are programmed to contract in response to specific wavelengths of light. By selectively shining light on one or both of the fins, researchers can dictate the frequency and force of the muscle contractions. This creates a rhythmic flapping motion, allowing the robot to steer, accelerate, or navigate complex underwater environments with surprising agility.
The results of initial trials were striking. In laboratory experiments, the robot successfully navigated a miniature underwater maze, demonstrating precision control that belies its simple construction. While its top speed—approximately four body lengths per minute—cannot compete with an Olympic athlete, it mimics the leisurely, efficient gait of a cow shark. For a device powered by a single layer of biological cells, this performance is a testament to the latent strength of organized muscle tissue.
Chronology of an Engineering Evolution
The road to this two-dimensional swimmer was paved by a previous, seminal project from the laboratory of Ritu Raman, an associate professor of mechanical engineering at MIT. Last year, the team sought to prove that thin layers of muscle could produce controlled, purposeful movement.
The Iris Prototype
The precursor to the swimming robot was an artificial muscle disk modeled after the human iris. In this experiment, the team patterned a gel disk with concentric circular grooves, seeding them with muscle cells. When exposed to light, the tissue contracted, causing the disk to expand and compress in a manner mirroring the human pupil. While the movement was precise, the scale was limited—the tissue moved only about 100 microns. From a robotics standpoint, the motion was microscopic, but it proved that engineers could "program" biological tissue to follow complex architectural patterns.
Transitioning to Propulsion
With the concept of patterned muscle growth validated, the team set their sights on a more ambitious goal: generating enough force to achieve locomotion in a fluid medium. Water presents a significant challenge for soft robotics; it is far denser than air, requiring substantial force to displace.
The transition from the iris disk to the swimming robot required a fundamental reassessment of the material science involved. The researchers realized that their previous foundation—fibrin, a very soft, protein-based gel—was insufficient. Under the persistent, rhythmic tension of muscle contractions, fibrin would shrink and deform, bleeding away the energy that should have been translated into movement.
The Optimization Phase
To overcome this, the researchers entered a rigorous phase of material optimization. They focused on three "tuning knobs": chemical composition, stiffness, and structural geometry. Through a systematic testing process, the team compared various groove shapes and material formulations. They discovered that square-bottomed channels encouraged the muscle cells to align in a singular direction, which is critical for the cells to fuse into fibers and generate coordinated, high-force contractions.
Furthermore, the team replaced the aging fibrin with gelatin methacrylate (GelMA), a biocompatible, synthetic polymer that could be tuned for specific stiffness levels. By finding the "Goldilocks" zone of material firmness and applying a regimen of light-induced "exercise" to the muscle cells before integration, they produced a stronger, more resilient biological actuator.
Supporting Data: The Power of Biological Efficiency
One of the most compelling aspects of the MIT study is the focus on efficiency. Existing biohybrid robots are typically three-dimensional, requiring millions of lab-grown muscle cells to function. These structures are often bulky, difficult to fabricate, and expensive to maintain.
Raman’s team argues that their two-dimensional approach is a paradigm shift. By utilizing a single, thin layer of cells, they have drastically reduced the manufacturing requirements while maintaining a high power-to-weight ratio.
- Mechanical Strength: Despite the microscopic thickness of the muscle layer, the force generated is sufficient to overcome fluid drag, allowing for stable navigation.
- Fabrication Efficiency: The move away from 3D-printed cell "chunks" to 2D-patterned films suggests a path toward mass-producing biohybrid components, similar to how microchips are fabricated on silicon wafers.
- Responsive Autonomy: Because the system uses living tissue, it is inherently adaptive. Unlike rigid metal, which is prone to fatigue and requires complex external sensors, muscle tissue is soft, sensitive to environmental cues, and capable of a degree of biological self-repair.
Official Perspectives: The Vision for Biohybrid Robotics
"It takes a lot of force to move through water versus air," notes Ritu Raman, the study’s lead author. "The robot’s quite strong, given its size."
Raman emphasizes that the goal is not to replace traditional machines, but to expand the definition of what a robot can be. "Currently, biohybrid robots from our group and others are built from bulky, 3D chunks of lab-grown skeletal muscle that require millions of cells to fabricate," she explains. "We believe that thinner, less bulky designs such as our new bot could be cheaper to build and could move more efficiently."
The implications of this research extend far beyond the laboratory petri dish. As the technology matures, Raman envisions a new class of robots capable of performing delicate tasks in environments that are currently inaccessible to rigid, conventional hardware. "Living tissue is soft, responsive to its surroundings, and can heal itself," Raman says. These properties make biohybrid robots uniquely suited for tasks such as exploring fragile coral reefs, monitoring chemical concentrations in unpredictable aquatic ecosystems, or navigating through tight, confined spaces where metal components might cause damage.
Future Implications and Technological Frontiers
The successful demonstration of the swimming robot is only the first step. The research team, which includes first author Maheera Bawa alongside colleagues Arielle Berman, Laura Schwendeman, Ferdows Afghah, and Seanbiron Johnson, is already looking toward the next phase of development.
Refining the Physiology
The immediate next step is to improve the robot’s velocity. While current iterations are functional, the team is experimenting with body geometry and muscle arrangement to optimize the thrust-to-drag ratio, aiming to achieve higher speeds without sacrificing the control provided by the optogenetic stimulation.
Environmental Monitoring
Beyond the engineering challenges, there is a clear roadmap for real-world application. As the technology advances, these robots could be deployed for environmental monitoring. Because they are constructed from biodegradable biological materials, they pose a significantly lower risk of environmental contamination compared to traditional plastic-and-metal drones.
A New Era of Soft Robotics
The MIT study marks a turning point in the field of soft robotics. By proving that living muscle can be engineered and "programmed" as effectively as a computer circuit, the researchers have opened the door to a future where robots are grown rather than built. As we move toward this future, the boundaries between the artificial and the biological will continue to blur, leading to a new generation of machines that are as dynamic and resilient as the life forms they imitate.
The research was supported by the Office of Naval Research, signaling a strategic interest in the potential for these devices to serve as the next generation of aquatic surveillance and exploration tools. As the team continues to refine their design, the humble, gum-stick-sized robot serves as a powerful reminder that sometimes, the most sophisticated machine is not made of metal, but of the very building blocks of life itself.
 Reynand Wu
 Ammar Sabilarrohman
 rifanmuazin
